Autonomous hauling
Designed to move materials along defined jobsite routes autonomously. Operating conditions will be confirmed through testing.
A compact construction material hauler designed for repeated trips along defined jobsite routes, with autonomous hauling, remote video control, and a powered dump bed.
Discuss Tera for your site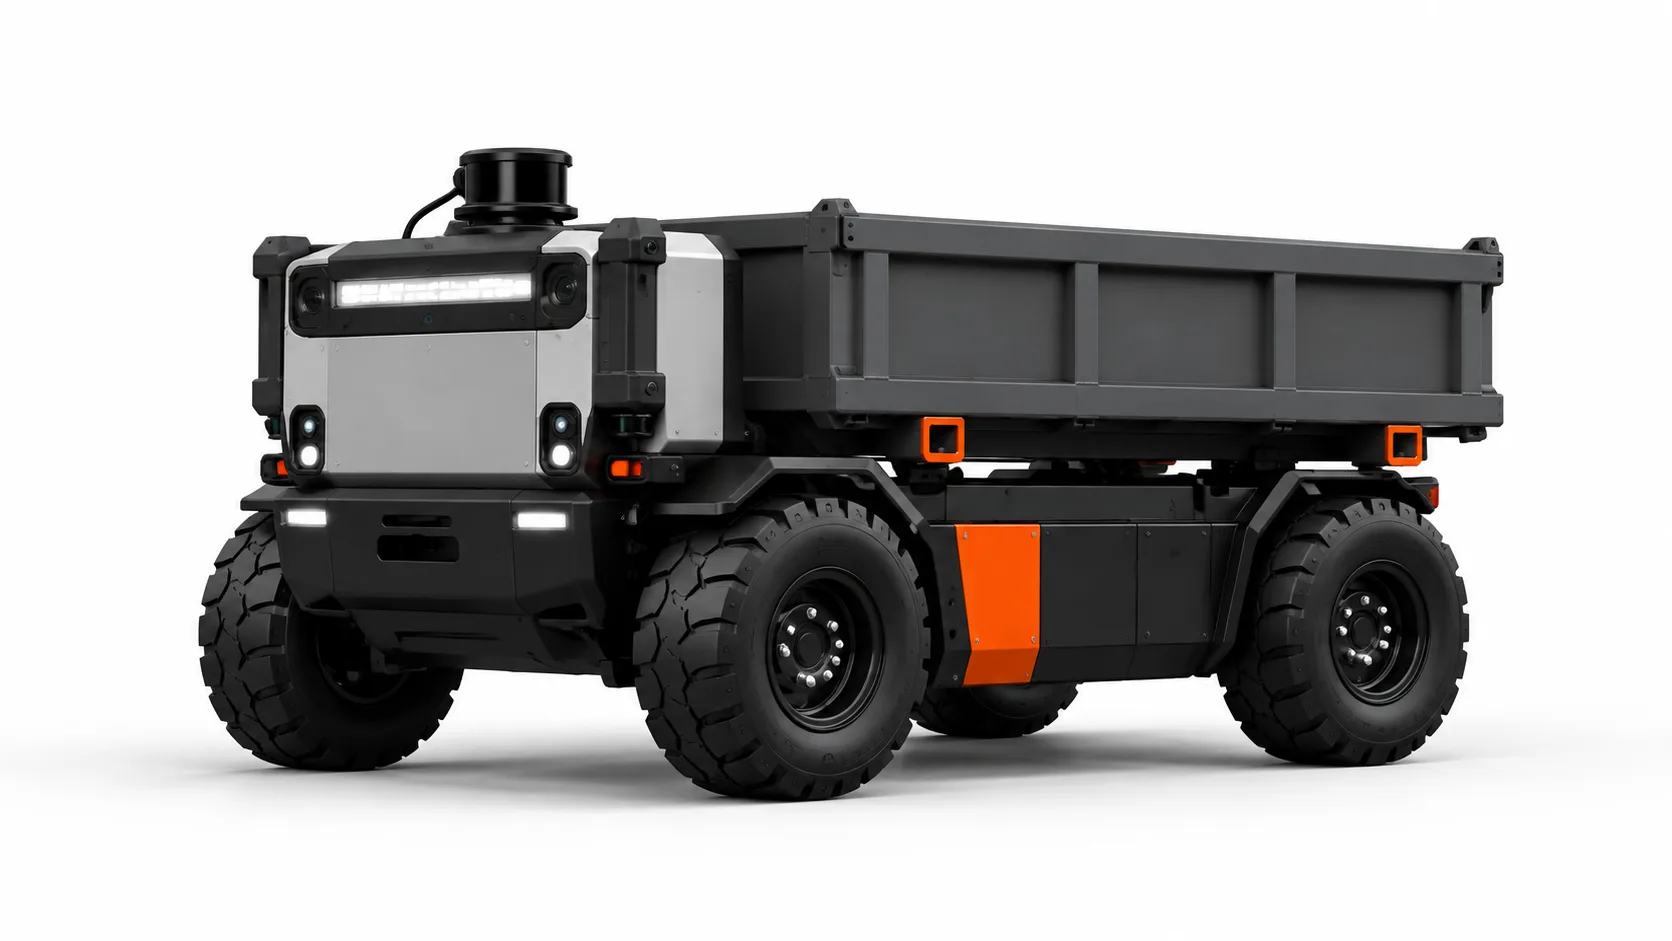
Tera targets a 30 in (760 mm) width, an 800 lb (360 kg) payload, and 6–8 hours of runtime. These are preliminary design targets; final performance and autonomous operating conditions require prototype and jobsite validation.
Designed to move materials along defined jobsite routes autonomously. Operating conditions will be confirmed through testing.
Drive and steer from a local Wi-Fi controller with selectable camera views and direct bed controls.
A 30 inch width target, four wheel drive, and electric power suit routes where a compact machine matters.
A rear pivot dump bed and 800 pound payload target support repeated material movement.
The proposed 10.1 inch controller combines a drive and steering joystick, bed controls, emergency stop, and selectable front, rear, left, and right camera views.
Remote video control goal: 165 ft (50 m) on representative jobsites; 330 ft (100 m) clear-line-of-sight stretch goal. These are unverified engineering targets, not an operating range. Final limits will be published after site testing.
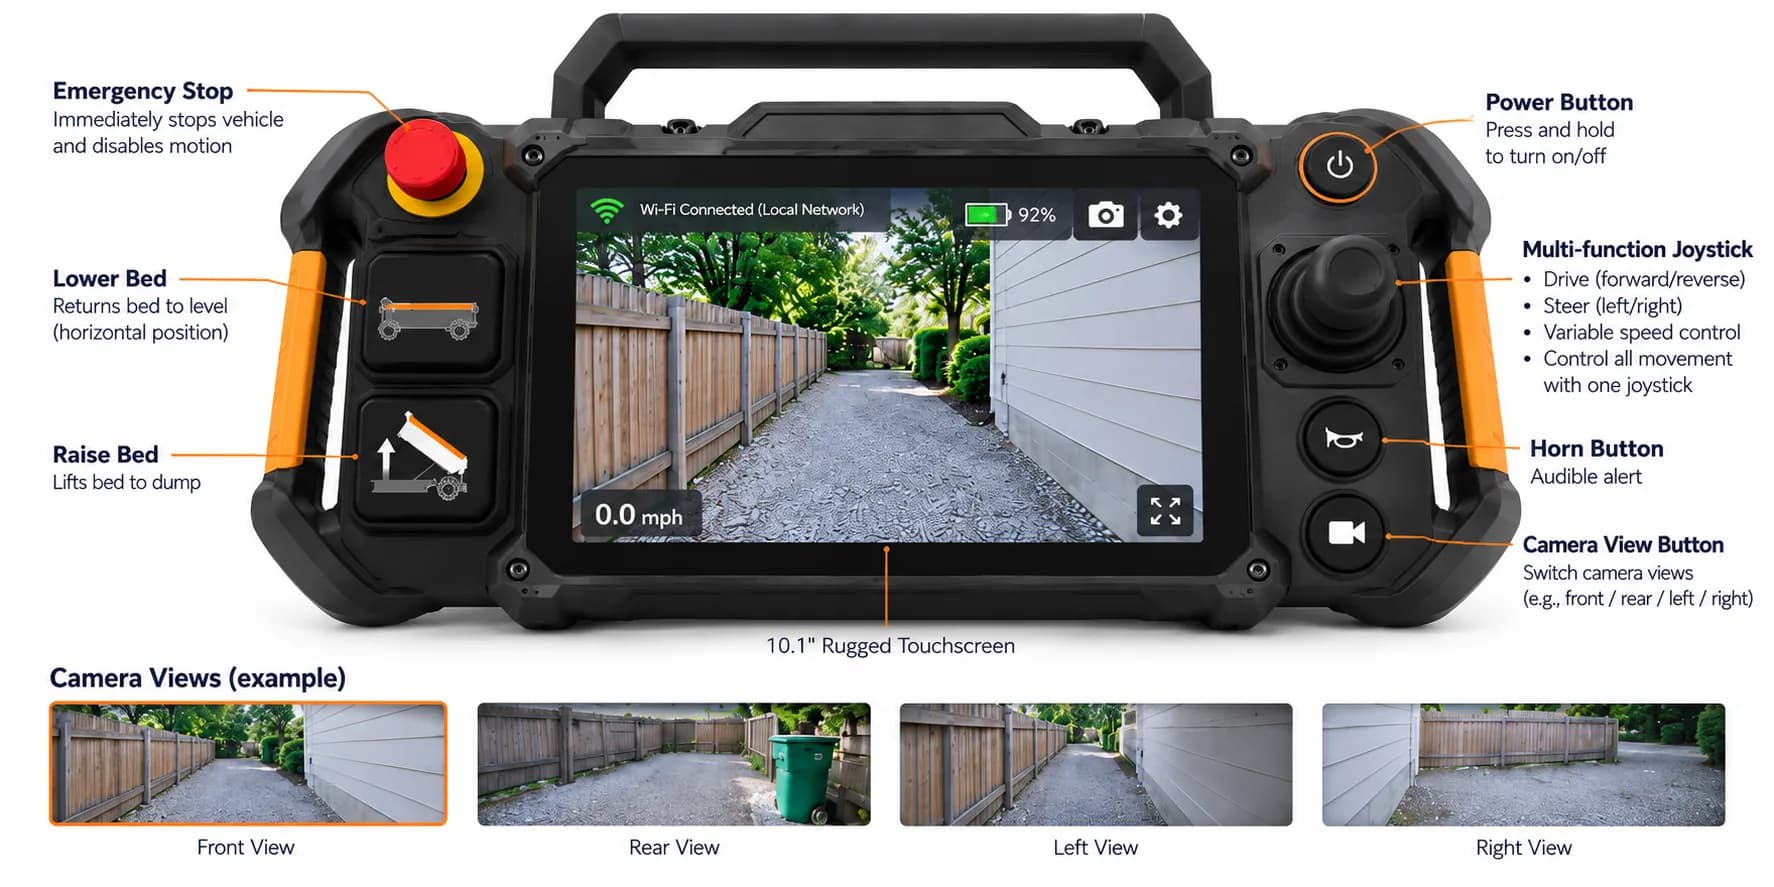
These preliminary dimensions, components, and control-distance goals will be confirmed after prototype and site validation. Control distance means usable live video and command response, not radio signal reach alone.
The design target is 800 lb (360 kg) of payload. The bed interior target is 47.2 × 27.6 × 11.8 in (1,200 × 700 × 300 mm). Load limits for specific materials and slopes still need validation.
Tera targets a 30 in (760 mm) overall width, about 6 in (150 mm) of ground clearance, four wheel drive, and pneumatic all-terrain tires. Turning radius, climbable grade, side slope, and surface limits have not been rated yet.
Tera is designed to move materials along defined jobsite routes. Route setup, supervision, operating conditions, and how it responds to people or obstacles must be established through testing before an autonomous operating rating is published.
The engineering goal is usable live video and control at 165 ft (50 m) on representative jobsites, with 330 ft (100 m) as a clear-line-of-sight stretch goal. These are unverified targets, not an operating range. Obstacles, interference, and video delay will affect the final rating.
The targets are 6–8 hours of runtime from a 48 V LFP battery and a powered rear-pivot dump bed. Runtime under a loaded duty cycle, charge time, and dumping limits on slopes remain to be tested.
The controller design includes an emergency stop. Connection-loss behavior and the full safety system still need validation before an operating rating is published.
Price, availability, purchase or rental options, warranty, and service terms have not been set. Contact us to discuss your jobsite and the next validation steps.
Share what you move, the route width and surface, and how often the trip happens. We can discuss how autonomous hauling and remote control would fit your site.
We review the application and discuss product timing, validation, and commercial terms when available.
Prefer email? robotics@motivegrid.com